载入中...
搜索中...
未找到
#include <AttitudeAircraftZDown.hpp>
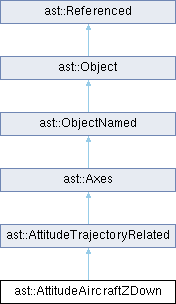
 类 ast::AttitudeAircraftZDown 继承关系图:
Public 成员函数 | |
| AttitudeAircraftZDown (Point *point, Body *body) | |
| errc_t | getTransform (const TimePoint &tp, Rotation &rotation) const override |
| errc_t | getTransform (const TimePoint &tp, KinematicRotation &rotation) const override |
| void | setBody (Body *body) |
| Public 成员函数 继承自 ast::AttitudeTrajectoryRelated | |
| AttitudeTrajectoryRelated (Point *point, Frame *frame) | |
| Axes * | getParent () const override |
| void | setPoint (Point *point) |
| void | setFrame (Frame *frame) |
| Point * | point () const |
| Frame * | frame () const |
| Public 成员函数 继承自 ast::Axes | |
| virtual errc_t | getTransform (const TimePoint &tp, AccelerationRotation &rotation) const |
| int | getDepth () const |
| Axes * | getAncestor (int depth) const |
| A_ALWAYS_INLINE errc_t | getTransformTo (Axes *target, const TimePoint &tp, Rotation &rotation) const |
| A_ALWAYS_INLINE errc_t | getTransformTo (Axes &target, const TimePoint &tp, Rotation &rotation) const |
| A_ALWAYS_INLINE errc_t | getTransformTo (Axes *target, const TimePoint &tp, KinematicRotation &rotation) const |
| A_ALWAYS_INLINE errc_t | getTransformTo (Axes &target, const TimePoint &tp, KinematicRotation &rotation) const |
| A_ALWAYS_INLINE errc_t | getTransformFrom (Axes *source, const TimePoint &tp, Rotation &rotation) const |
| A_ALWAYS_INLINE errc_t | getTransformFrom (Axes &source, const TimePoint &tp, Rotation &rotation) const |
| A_ALWAYS_INLINE errc_t | getTransformFrom (Axes *source, const TimePoint &tp, KinematicRotation &rotation) const |
| A_ALWAYS_INLINE errc_t | getTransformFrom (Axes &source, const TimePoint &tp, KinematicRotation &rotation) const |
| A_ALWAYS_INLINE errc_t | getTransformFrom (Axes *source, const TimePoint &tp, AccelerationRotation &rotation) const |
| A_ALWAYS_INLINE errc_t | getTransformFrom (Axes &source, const TimePoint &tp, AccelerationRotation &rotation) const |
| A_ALWAYS_INLINE errc_t | getTransformFromParent (const TimePoint &tp, Rotation &rotation) const |
| A_ALWAYS_INLINE errc_t | getTransformFromParent (const TimePoint &tp, KinematicRotation &rotation) const |
| errc_t | getAttitudeIn (Axes &axes, const TimePoint &tp, Quaternion &quat) const |
| A_ALWAYS_INLINE errc_t | getAttitudeIn (Axes *axes, const TimePoint &tp, Quaternion &quat) const |
| errc_t | getAttitudeIn (Axes &axes, const TimePoint &tp, Quaternion &quat, Vector3d &angvel) const |
| A_ALWAYS_INLINE errc_t | getAttitudeIn (Axes *axes, const TimePoint &tp, Quaternion &quat, Vector3d &angvel) const |
| Public 成员函数 继承自 ast::ObjectNamed | |
| ObjectNamed ()=default | |
| ObjectNamed (StringView name) | |
| const std::string & | getName () const override |
| void | setName (StringView name) override |
| Public 成员函数 继承自 ast::Object | |
| Object (Object *parentScope) | |
| Object (std::nullptr_t) | |
| virtual Class * | getType () const |
| virtual std::string | getRepresentation () const |
| const std::string & | name () const |
| std::string | displayName () const |
| errc_t | showEditDialog () |
| Attribute | attr (StringView path) |
| errc_t | getAttrBool (StringView path, bool &value) const |
| errc_t | getAttrInt (StringView path, int &value) const |
| errc_t | getAttrDouble (StringView path, double &value) const |
| errc_t | getAttrString (StringView path, std::string &value) const |
| errc_t | getAttrObject (StringView path, Object *&value) const |
| double | getAttrDouble (StringView path) const |
| int | getAttrInt (StringView path) const |
| bool | getAttrBool (StringView path) const |
| std::string | getAttrString (StringView path) const |
| Object * | getAttrObject (StringView path) const |
| errc_t | setAttrBool (StringView path, bool value) |
| errc_t | setAttrInt (StringView path, int value) |
| errc_t | setAttrDouble (StringView path, double value) |
| errc_t | setAttrString (StringView path, StringView value) |
| errc_t | setAttrObject (StringView path, Object *value) |
| Class * | type () const |
| const std::string & | typeName () const |
| Property * | getProperty (StringView fieldName) const |
| ObjectId | getID () const |
| errc_t | setParentScope (Object *parentScope) |
| Object * | getParentScope () const |
| template<typename T > | |
| T | getParent () const |
| bool | isOfType (const Class *type) const |
| bool | isOfType (StringView typeName) const |
| template<typename T > | |
| bool | isOfType () const |
| template<typename Func > | |
| void | addDelayedLink (Func &&link) |
| template<typename Func > | |
| void | addDelayedLinkIfFailed (Func &&link) |
| void | resolveLinks () |
| bool | readOnly () const |
| void | setReadOnly (bool readOnly) |
| bool | active () const |
| void | setActive (bool active) |
| bool | isComponent () const |
| void | setIsComponent (bool isComponent) |
| bool | isEntity () const |
| void | setIsEntity (bool isEntity) |
| const char * | tr (const char *msg) const |
| Referenced () | |
| Referenced (initial_strong_ref_t) | |
| Public 成员函数 继承自 ast::Referenced | |
| Referenced (initial_strong_ref_t) | |
| uint32_t | refCount () const |
| uint32_t | weakRefCount () const |
| bool | isDestructed () const |
| void | destruct () |
| uint32_t | incWeakRef () |
| uint32_t | decWeakRef () |
| uint32_t | incRef () |
| uint32_t | decRef () |
| uint32_t | decRefNoDelete () |
额外继承的成员函数 | |
| 静态 Public 成员函数 继承自 ast::Object | |
| static Object * | Resolve (StringView value) |
| static void | ClassInit (Class *cls) |
| static Class * | StaticType () |
| 静态 Public 属性 继承自 ast::Object | |
| static Class | staticType |
| Protected 成员函数 继承自 ast::AttitudeTrajectoryRelated | |
| errc_t | getPosVelAccLocal (const TimePoint &tp, Vector3d &pos, Vector3d &vel, Vector3d &acc) const |
| errc_t | getPosVelLocal (const TimePoint &tp, Vector3d &pos, Vector3d &vel) const |
| errc_t | getPosLocal (const TimePoint &tp, Vector3d &pos) const |
| Protected 成员函数 继承自 ast::Object | |
| Object (const Object &) | |
| Object & | operator= (const Object &) |
| Protected 成员函数 继承自 ast::Referenced | |
| void | setDestructed () |
详细描述
对地指向 + ECF 速度约束的机体 Z 朝下姿态
"ECF Velocity Alignment with Nadir Constraint" 即飞机、船舶、地面车辆等"大圆弧载体"的默认姿态: 体 X 轴严格对齐地固系速度方向(机头指向),体 Z 轴在保持 X 轴对齐的前提下尽量指向地心 (机体 Z 朝下)
成员函数说明
◆ getTransform() [1/2]
|
overridevirtual |
◆ getTransform() [2/2]
该类的文档由以下文件生成:
- src/AstCore/Attitude/AttitudeAircraftZDown.hpp
- src/AstCore/Attitude/AttitudeAircraftZDown.cpp
