|
|
| StateBPlane (const BPlaneElem &bPlaneElem) |
| |
|
| StateBPlane (const State &state) |
| |
| EStateType | getStateType () const override |
| |
| errc_t | getState (CartState &state) const override |
| |
| errc_t | getState (ModOrbElem &orbElem) const override |
| |
| errc_t | setState (const CartState &state) override |
| |
| errc_t | setState (const ModOrbElem &orbElem) override |
| |
| void | getState (BPlaneElem &bPlaneElem) const |
| |
| errc_t | setState (const BPlaneElem &bPlaneElem) |
| |
| errc_t | getRefVector (Vector3d &refVector, const CartState *cartState=nullptr) const |
| |
| void | setRefVector (EBPlaneRefVector refVectorType, const Vector3d &refVector=Vector3d::Zero()) |
| |
| EBPlaneRefVector | getRefVectorType () const |
| |
| errc_t | getStateIn (Body *body, GeodeticPoint &geodetic) const |
| |
| errc_t | getStateIn (Frame *frame, ModOrbElem &orbElem) const |
| |
| errc_t | getStateIn (Frame *frame, CartState &state) const |
| |
| errc_t | getStateInBodyInertial (Body *body, CartState &state) const |
| |
| errc_t | setFrameByName (StringView frameName) |
| |
| errc_t | changeFrame (Frame *frame) |
| |
| void | setStateEpoch (const TimePoint &stateEpoch) |
| |
|
TimePoint | getStateEpoch_TimePoint () const |
| |
| errc_t | getStateEpoch (TimePoint &stateEpoch) const |
| |
| SharedPtr< EventTime > & | getStateEpochHandle () |
| |
|
Body * | getBody () const |
| |
| double | getBodyRadius () const |
| |
| double | getGM () const |
| |
| void | setGM (double gm) |
| |
|
void | setFrame (Frame *frame) |
| |
|
EventTime * | getStateEpoch () const |
| |
| void | setStateEpoch (EventTime *stateEpoch) |
| |
|
| ObjectNamed ()=default |
| |
| | ObjectNamed (StringView name) |
| |
| const std::string & | getName () const override |
| |
| void | setName (StringView name) override |
| |
|
| Object (Object *parentScope) |
| |
|
| Object (std::nullptr_t) |
| |
| virtual Class * | getType () const |
| |
| virtual std::string | getRepresentation () const |
| |
|
const std::string & | name () const |
| |
|
std::string | displayName () const |
| |
| errc_t | showEditDialog () |
| |
| Attribute | attr (StringView path) |
| |
| errc_t | getAttrBool (StringView path, bool &value) const |
| |
| errc_t | getAttrInt (StringView path, int &value) const |
| |
| errc_t | getAttrDouble (StringView path, double &value) const |
| |
| errc_t | getAttrString (StringView path, std::string &value) const |
| |
| errc_t | getAttrObject (StringView path, Object *&value) const |
| |
| double | getAttrDouble (StringView path) const |
| |
| int | getAttrInt (StringView path) const |
| |
| bool | getAttrBool (StringView path) const |
| |
| std::string | getAttrString (StringView path) const |
| |
| Object * | getAttrObject (StringView path) const |
| |
| errc_t | setAttrBool (StringView path, bool value) |
| |
| errc_t | setAttrInt (StringView path, int value) |
| |
| errc_t | setAttrDouble (StringView path, double value) |
| |
| errc_t | setAttrString (StringView path, StringView value) |
| |
| errc_t | setAttrObject (StringView path, Object *value) |
| |
| Class * | type () const |
| |
|
const std::string & | typeName () const |
| |
| Property * | getProperty (StringView fieldName) const |
| |
| ObjectId | getID () const |
| |
| errc_t | setParentScope (Object *parentScope) |
| |
| Object * | getParentScope () const |
| |
|
template<typename T > |
| T | getParent () const |
| |
| bool | isOfType (const Class *type) const |
| |
| bool | isOfType (StringView typeName) const |
| |
| template<typename T > |
| bool | isOfType () const |
| |
| template<typename Func > |
| void | addDelayedLink (Func &&link) |
| |
| template<typename Func > |
| void | addDelayedLinkIfFailed (Func &&link) |
| |
| void | resolveLinks () |
| |
|
bool | readOnly () const |
| |
|
void | setReadOnly (bool readOnly) |
| |
|
bool | active () const |
| |
|
void | setActive (bool active) |
| |
|
bool | isComponent () const |
| |
|
void | setIsComponent (bool isComponent) |
| |
|
bool | isEntity () const |
| |
|
void | setIsEntity (bool isEntity) |
| |
|
const char * | tr (const char *msg) const |
| |
|
| Referenced () |
| |
| | Referenced (initial_strong_ref_t) |
| |
| | Referenced (initial_strong_ref_t) |
| |
| uint32_t | refCount () const |
| |
| uint32_t | weakRefCount () const |
| |
| bool | isDestructed () const |
| |
| void | destruct () |
| |
| uint32_t | incWeakRef () |
| |
| uint32_t | decWeakRef () |
| |
| uint32_t | incRef () |
| |
| uint32_t | decRef () |
| |
| uint32_t | decRefNoDelete () |
| |
B平面状态
B平面状态使用入渐近线方向和B矢量描述航天器相对中心天体的状态, 主要用于双曲线到达轨迹(月球或行星借力飞越)。 具体的转换算法和退化处理参见 aCartToBPlane 和 aBPlaneToCart 。
- 注解
- 该状态需要参考坐标系(提供中心天体与引力常数)和状态历元: 默认参考向量(B平面R、T轴的定义依据)为中心天体绕其父天体的轨道法向, 需要星历数据支持, 可通过 setRefVector 修改。
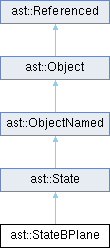
 类 ast::StateBPlane 继承关系图: